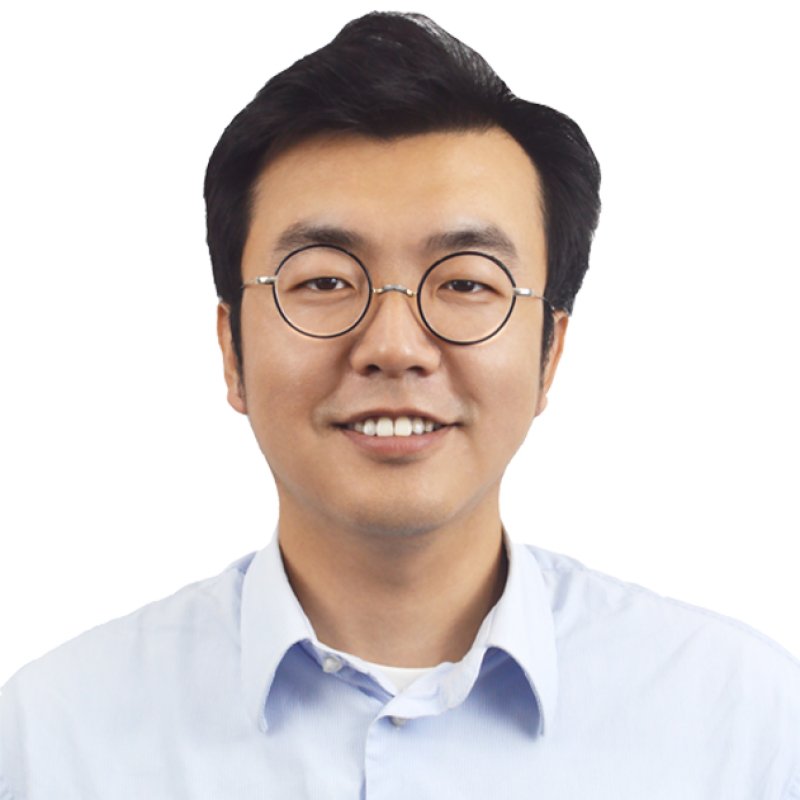
冀晓强教授在美国哥伦比亚大学获得博士学位����,现任香港中文大学(丽江)助理教授、博士生导师����,Z6官网具身智能中心副主任����,广东省具身智能机械人创新中心、工程技术钻研中心及工程钻研中心副主任����,中国仿真学会智能物联专委会委员����,东盟 - 中国人为智能尝试室首席科学家������。
他的钻研重要集中在人为智能节造系统����,主持多项科研及人才项目����,蕴含国度天然科学基金数据科学与人为智能前沿索求课题、广东省面上、丽江市沉大等项目������。至今在IEEE Transactions on Automatic Control (TAC)、Automatica、Journal of Field Robotics (JFR)、ACM T-CPS、IEEE/ASME T-Mech、T-ASE、RA-L、CDC、ICRA等顶尖国际期刊及会议颁发论文六十余篇����,1本专著������。出格是在非最幼相位系统方面����,是该领域全球领域内进建节造设计的推动者之一������。他担任蕴含IEEE-TAC在内的多个顶级期刊及会议的审稿人、MECC副编纂、Robot Learning青年编委、RCAR等国际会议领域主席����,并于近期获得CINT优良论文奖、ISUI最佳论文奖、Wiley中国高贡献作者奖等������。
冀教授携带的人为智能节造与决策尝试室����,是一个学科交叉平台����,必要深度融合节造论、人为智能、机械人学、高机能推算、大数据等基础科学����,致力于发展人为智能与智能系吐潇域的基础理论与原创性钻研������。
学术领域(最多选择3项):
- 人为智能与机械人
- 推算机工程
- 电子工程
- 化学
- 数学与利用数学
- 资料学
- 新能源科学与工程
- 物理
幼我网站:
https://cnd-lab.github.io/
专著:
· Xiaoqiang Ji, Y. Chen, Y. Chen, and S. Liu. Embodied�Intelligent Dexterous Hand Manipulation (in Chinese), PHEI 电子工业出版社.
Research Paper: (*Correspondence author)
- Xiaoqiang Ji*, Y. Dou, S. Zhu and Y. Xu. Unified feedforward control framework for disturbed nonminimum phase systems: the Koopman-type inverse operator approach. IEEE Transactions on Automatic Control, vol. 71, no. 7, pp. 4858-4864, July 2026.
- Z. Lin, Z.Wei, Y.Zhong, N. Ding Y.Zhao and Xiaoqiang Ji*. ALICE: Autonomous lifelong intelligence framework for cross-embodiment via continuous internal states feedback mechanism. Future Generation Computer Systems, vol 186, Jan. 2027, 108730.
- H.Yu, S.Zhu, Z.Sun and Xiaoqiang Ji*. Online stable inversion of non-minimum phase systems with guaranteed stability via terminal-constrained MPC. IEEE 65th Conference on Decision and Control (CDC), 2026, accepted.
- S. Zhu, Xiaoqiang Ji*, R. Longman, and Y. Xu. Presicion tracking for non-minimum phase LPTV systems via a lifted time stable inversion. IEEE Transactions on Automatic Control, 10.1109, pp. 1-8, 2025.
- H.Wan, Y.Zhang, J.Wang, D.Wu, M.Li, X.Chen, Y.Deng, Y.Huang, Z.Sun, L. Zhang and Xiaoqiang Ji*. Toward universal embodied planning in scalable heterogeneous collaboration and control, Journal of Field Robotics (JFR), 1556-4959, 2025.
- Xiaoqiang Ji*, S. Zhu, Y. Xu, and R. Longman. Lifted time stable inversion based feedforward control for linear non-minimum phase systems, Automatica, vol. 171, pp. 111979, 2025.
- H.Wan, J.Cheng, Y.Deng, D.Wu, Y.Chen, Z.Lin, J.Liu, J.Yu and Xiaoqiang Ji*. Towards physics aware embodied control with grapth based object-centric learning, ACM Transactions on Cyber-Physical Systems, Sep 2025.
- H.Wan, Y.Chen, Y.Deng, Z.Wei, D.Li, Z.Lin, D.Wu, J.Cheng, and Xiaoqiang Ji*. EmbodiedAgent: A scalable hierarchical approach to overcome practical challenge in multi-robot control, 2025 IEEE/RSJ Internaitonal Conference on Intelligent Robots and Systems (IROS), accepted, 2025.
- S.Zhu, Xiaoqiang Ji*, R. Longman, and Y. Xu. Lifted time stable inversion based high precision feedforward control for non-minimum phase systems, IEEE 63rd Conference on Decision and Control (CDC), December 16-19, 2024.
- Xiaoqiang Ji, X.Zhang, S.Zhu, F.Deng and B.Zhu. Data-driven adaptive consensus control for heterogeneous nonlinear multi-agent systems using online reinforcement learning, Neurocomputing, Vol. 596, 127818, 2024.
- J.Li, C.Zhao, Xiaoqiang Ji*, M.Li, G.Lu, Y.Xu, and D.Zhang. Multi-view instance attention fusion network for classification, Information Fusion, Vol. 101, 101974, 2024.
- K.Xue, Xiaoqiang Ji*, D.Qu, Y.Peng and H.Qian*. Oboat: An agile omnidirectional robotic platform for unmanned surface vehicle tasks, IEEE/ASME Transactions on Mechatronics (T-Mech), vol.28, no.5, pp.2413-2424, Oct. 2023.
- S. Zhu, Y. Wang, B. Zhu, and Xiaoqiang Ji*. Tracking error boundary of novel stable inversion based feedforward control for a class of non-minimum phase systems, CINT, vol 1714, Springer, 2023. [ Excellent Paper Award]
- K.Xue, C.Ren, Xiaoqiang Ji*, and H. Qian*. Design, modeling and implementation of a projectile-based mechanism for USVs charging tacks, IEEE Robotics and Automation Letters (RA-L),vol. 8, no. 1, pp. 360-367, Jan. 2023.
- K.Xue, J. Liu, N. Xiao, Xiaoqiang Ji*, and H. Qian*. A bio-inspired simultaneous surface and underwater risk assessment method based on stereo vision for USVs in nearshore clean waters, IEEE Robotics and Automation Letters (RA-L), 2022.
- Xiaoqiang Ji*, and R. Longman. Two new stable inverses of discrete time systems, Astrodynamics Specialist Conference, AAS/American Institute of Aeronautics and Astronautics (AIAA), vol. 171(1), 2020, pp. 4137-4143.